Nov 29, 2019

HEXA gait robot + FPV camera

- Straight path autonomous driving of HEXA gait robot with FPV camera
- Component:


- Video clip:


- Robot URL: http://arcbotics.com/products/hexy/

Nov 1, 2019

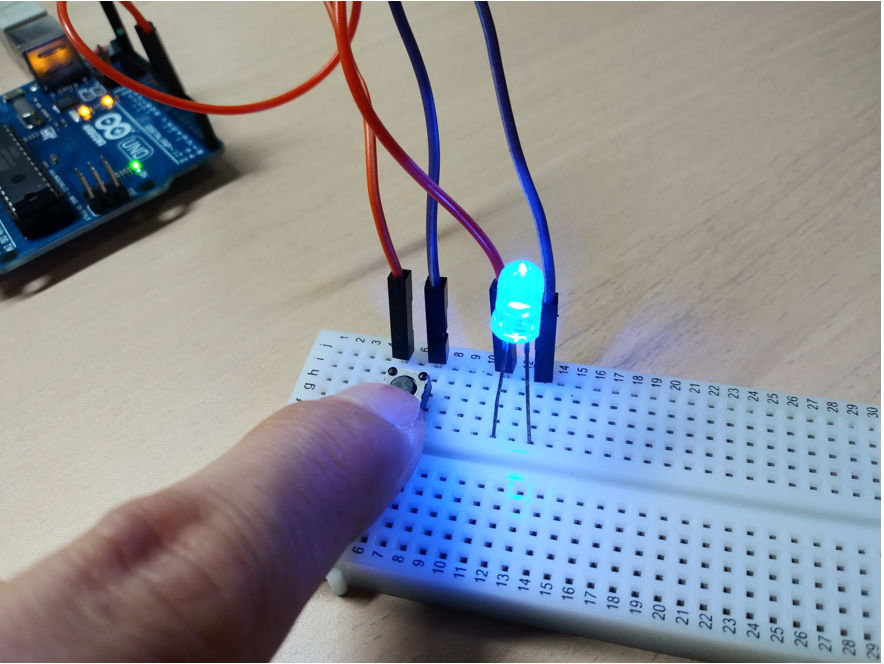
[Arduino code] LED turn on/off using a switch (스위치를 이용해 LED 켜고/끄기 아두이노 예제)

- Supplies: Arduino, LED, switch, jumper wire, breadboard
- 준비물: 아두이노, LED, 스위치, 전선

Connected configuration (연결 상태)

           
           Turn off (LED 끄기)
Turn on (LED 켜기)

// LED pin #
int LED_pin = 3;

// Switch pin#
int switch_pin = 5;

void setup() {
  // put your setup code here, to run once:
  pinMode(LED_pin, OUTPUT);
  pinMode(switch_pin, INPUT_PULLUP);

}

Oct 1, 2019

Pololu single motor driver - DRV8838 - Arduino code (모터 드라이버)


- Simple Arduino code to operate a DC motor with the motor driver.
- 1개의 DC 모터를 구동시키기 위해 모터 드라이버를 이용하는 간단한 아두이노 코드.
int Enable_pin = 9;
int Phase_pin = 8;

void setup() {
  // put your setup code here, to run once:
  pinMode(Enable_pin, OUTPUT);
  pinMode(Phase_pin, OUTPUT);
}

Sep 30, 2019

DASH gait robot

- Autonomous Driving of DASH gait robot
- Coordination and free body diagram of the unicycle model


- Error dynamics and linearization based controller


- Simulation result


- Video clip and experimental result


Sep 11, 2019

Tail wing mechanism moved by universal joint or servo motor. (유니버셜 조인트 또는 서보모터로 동작하는 꼬리 날개 메커니즘)

- The universal joint is made by a 3D printer.
- Spring and MDF-link are used to make the tail wing mechanism.

Detailed components

Side-view of a tail wing with universal joint

Top-view of a tail wing with universal joint

Video clip of tail wing movement